Unsupervised learning · Morphogenetic Programming · UCL · 2025
VoxelMorph.
A self-organising map, implemented in C#, that morphs between iconic buildings and maps every shape in between.
Unsupervised learning · Morphogenetic Programming · UCL · 2025
A self-organising map, implemented in C#, that morphs between iconic buildings and maps every shape in between.
Self-organising map
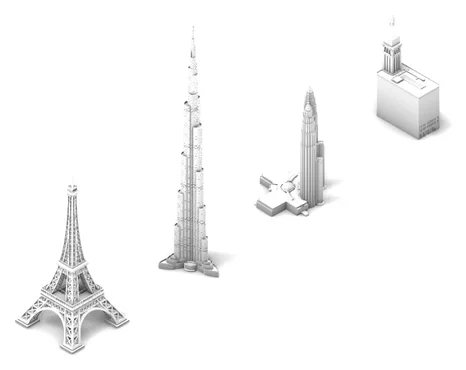
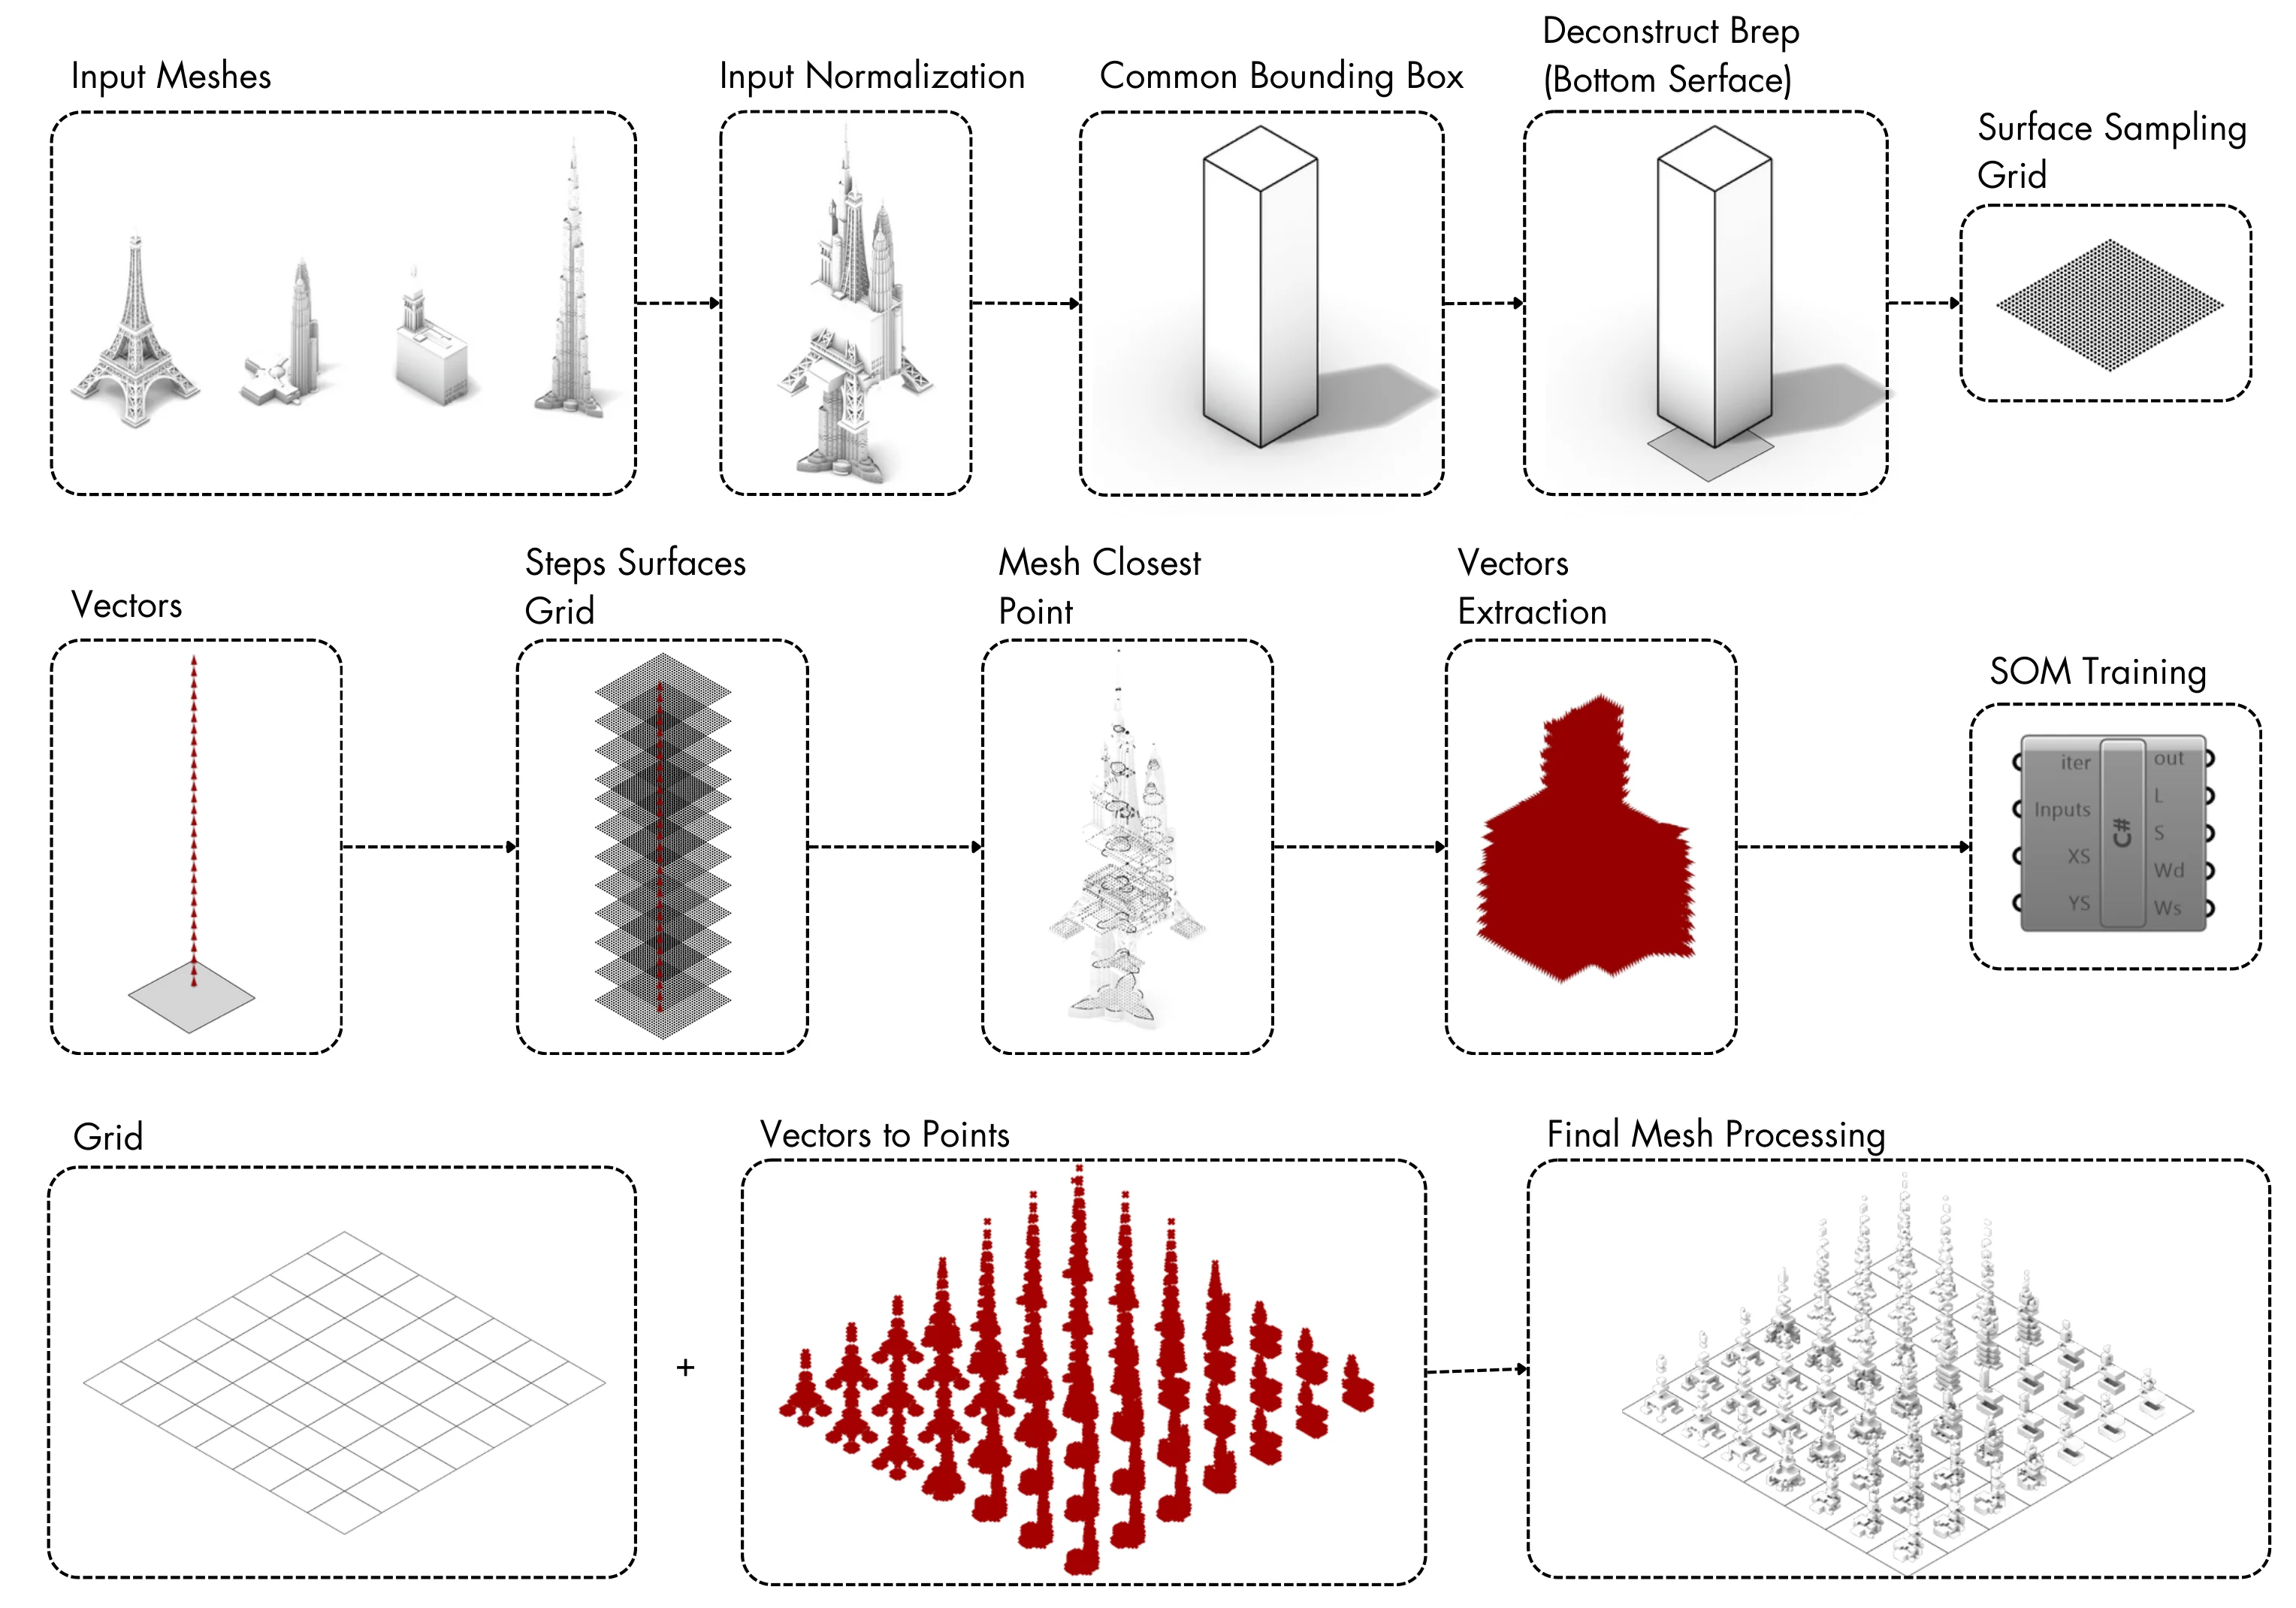
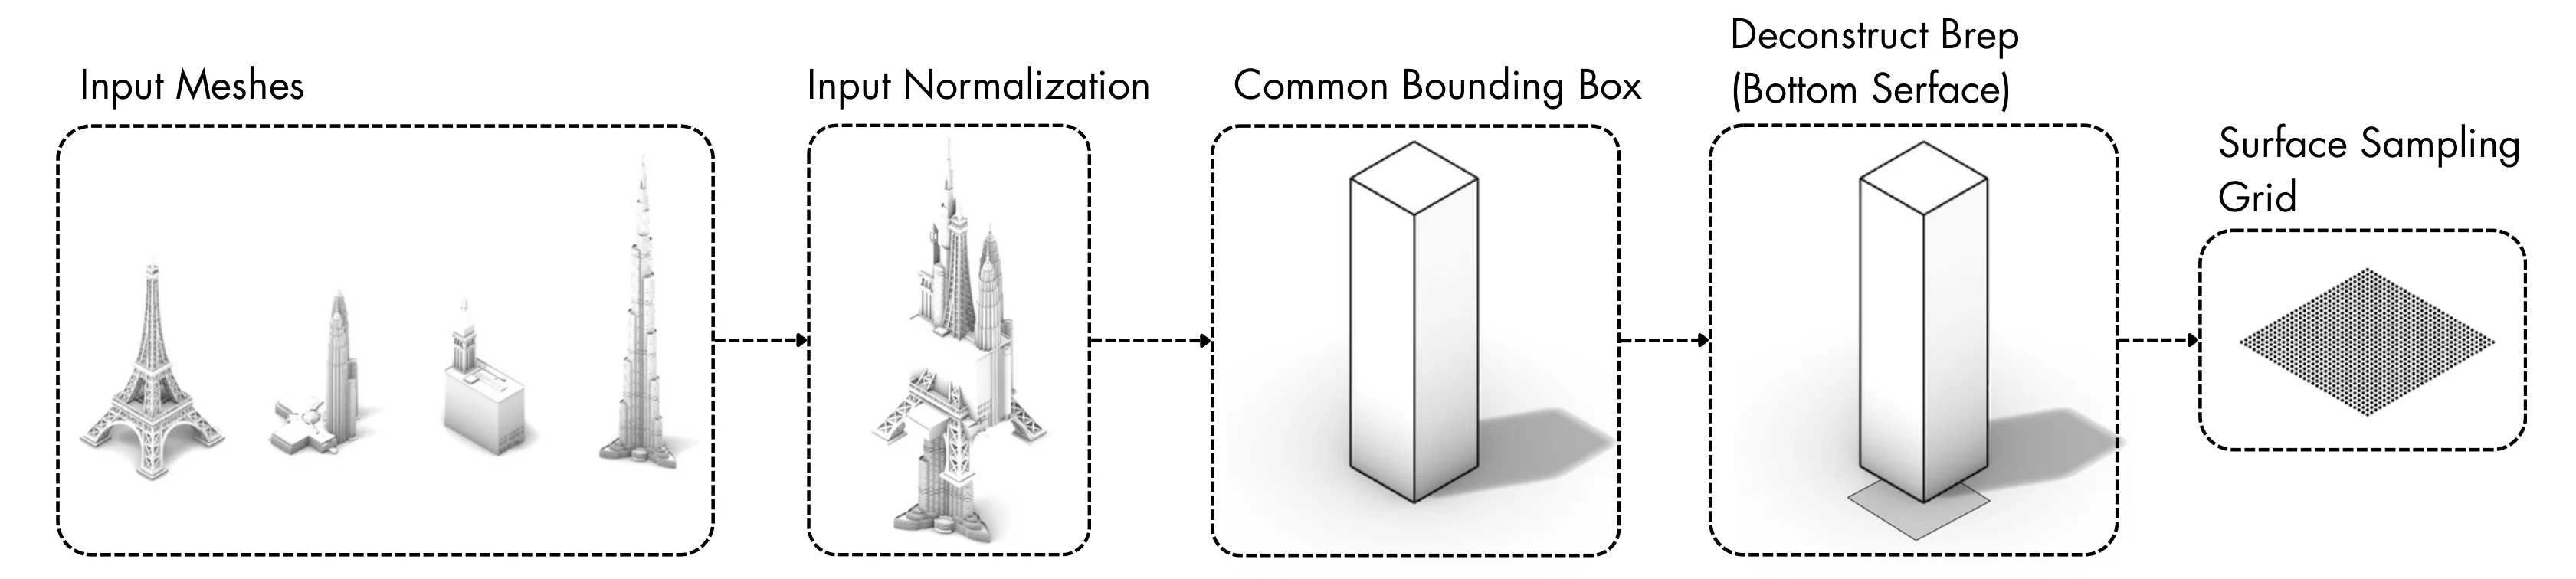
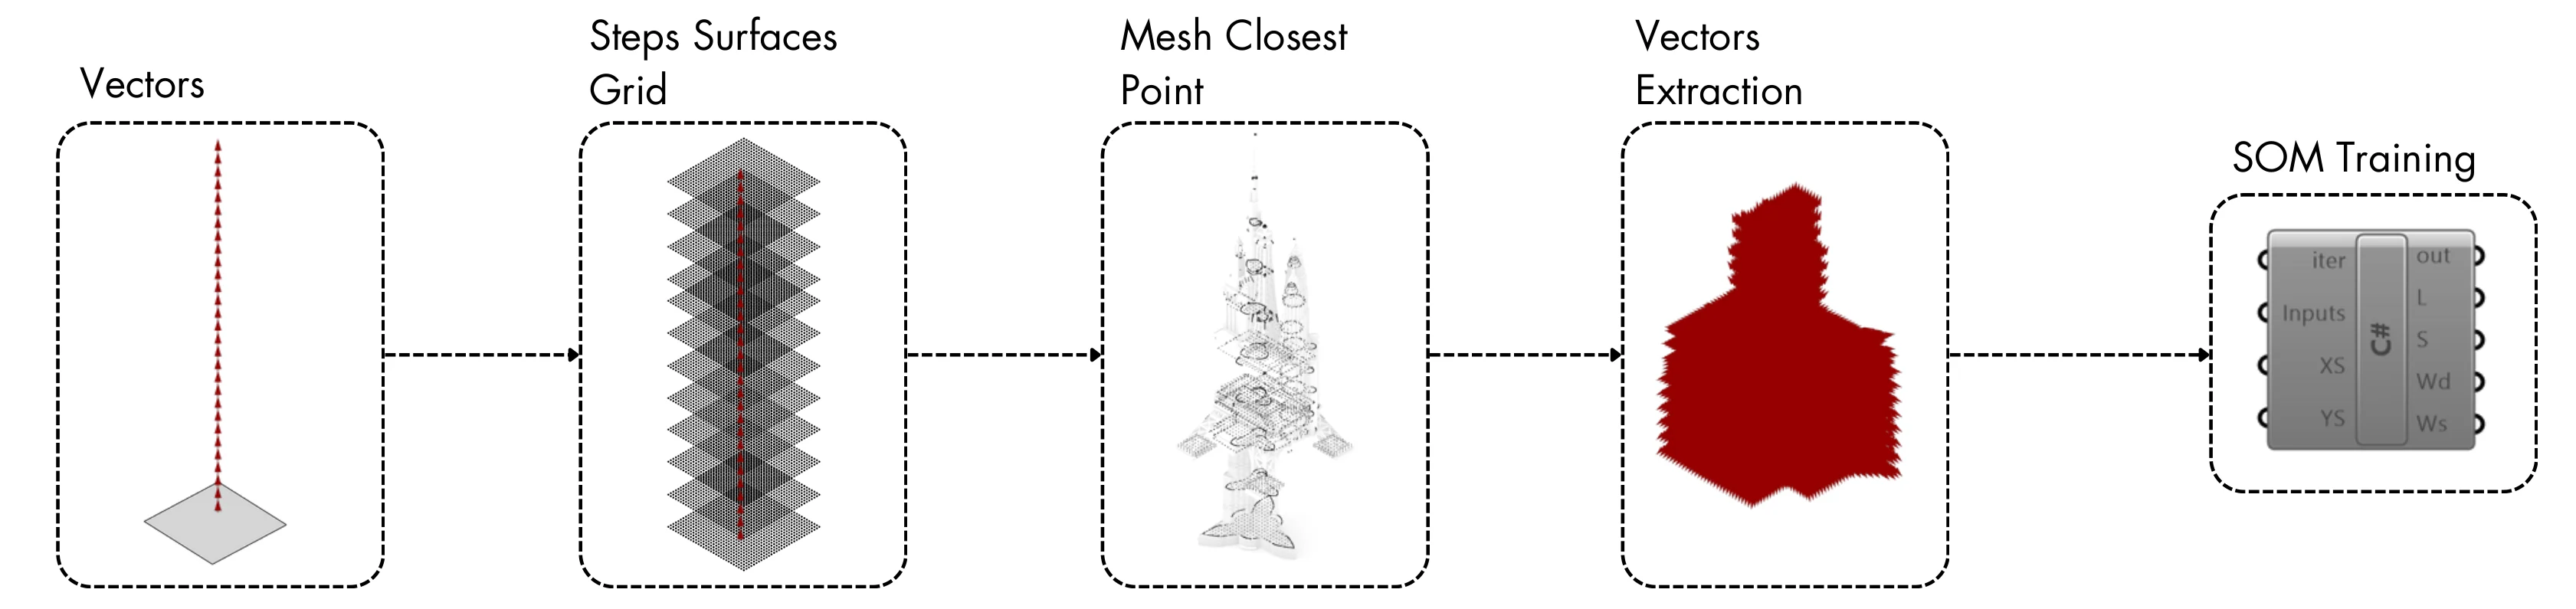
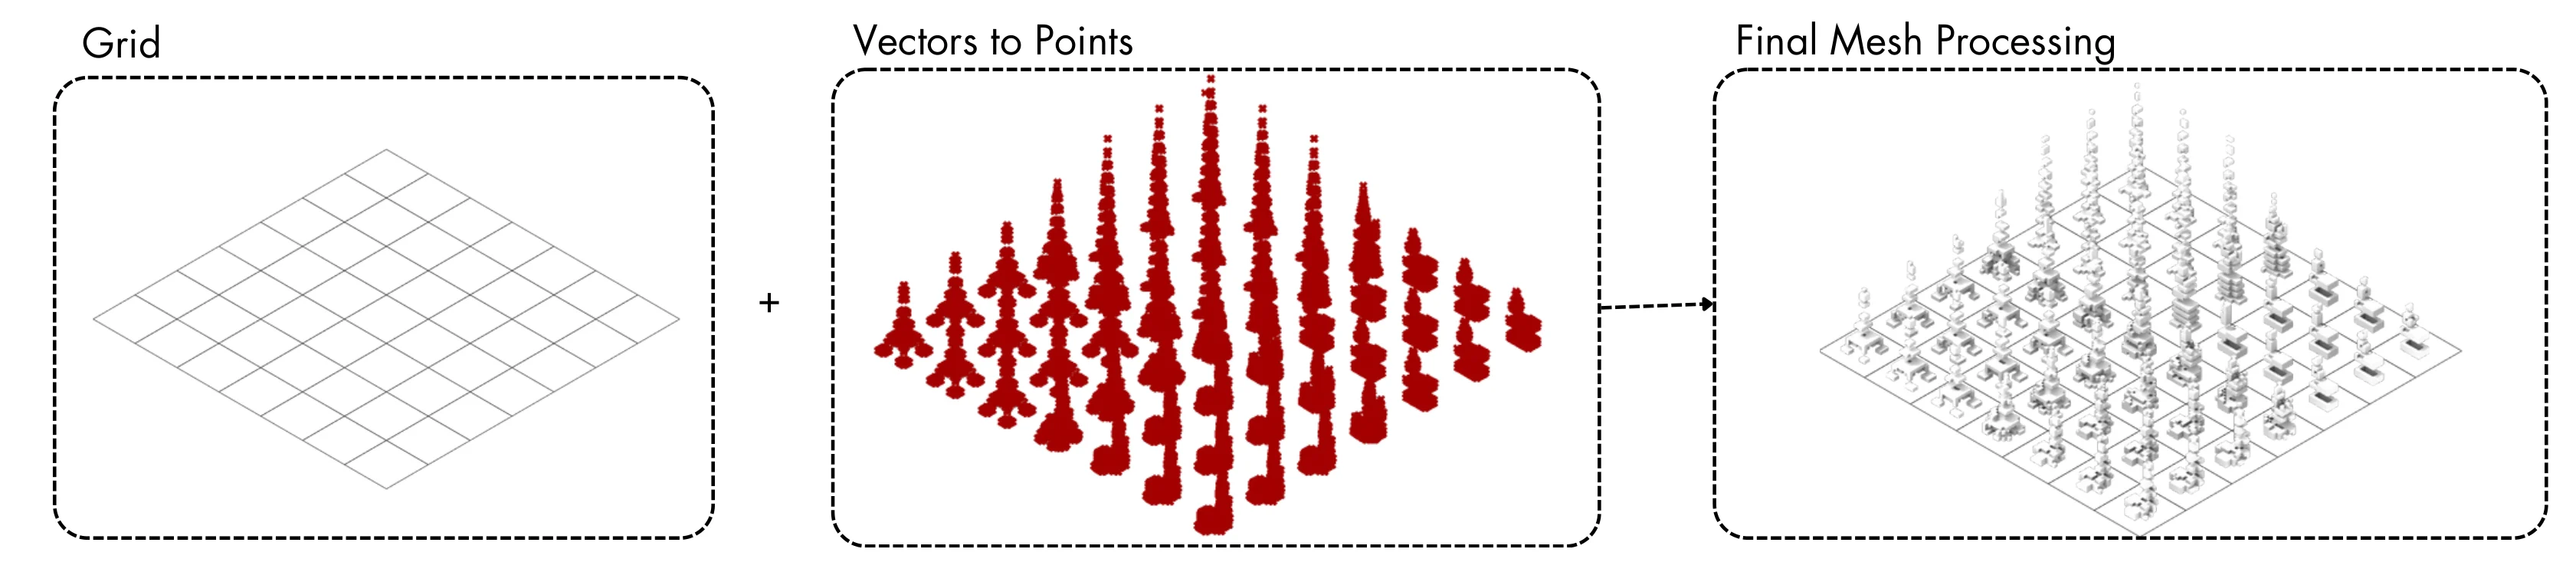
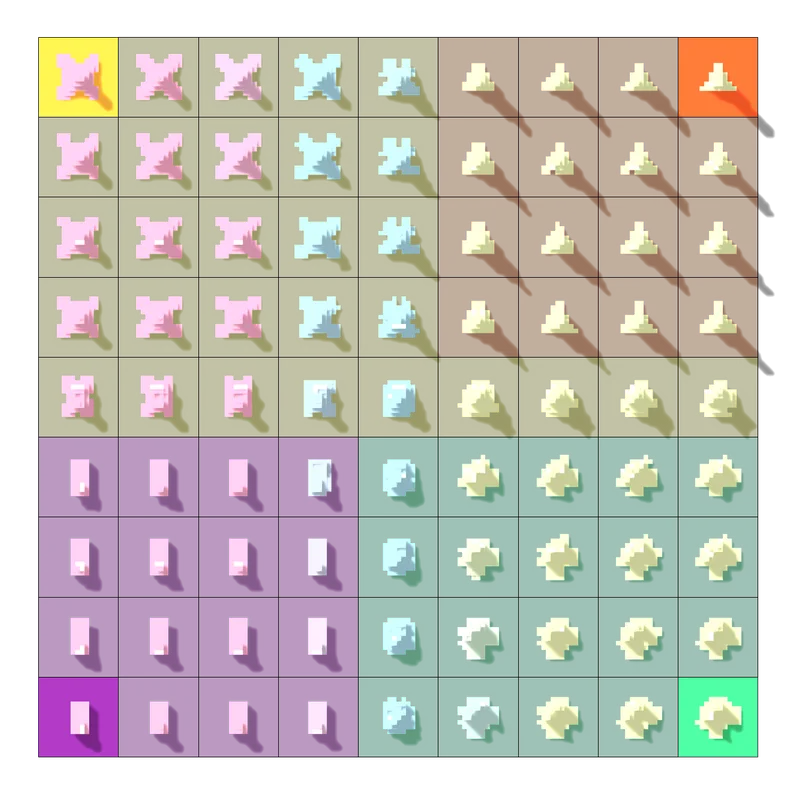
Four input meshes, centred in one bounding box, sampled on a 26 × 26 grid through 25 steps, closest-point vectors, a 10 × 10 self-organising map trained for 100 epochs, then voxelised at size 15.
Method
Four input meshes are normalised into one bounding box, probed by a grid of vertical vectors, encoded as displacement vectors, trained in a self-organising map written in C#, and decoded back into meshes on a grid.
Results
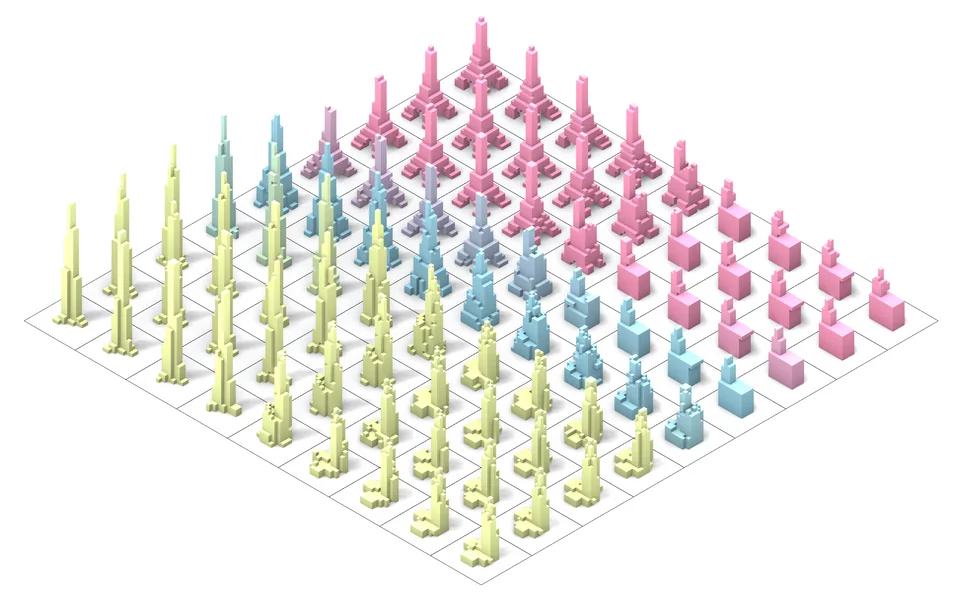
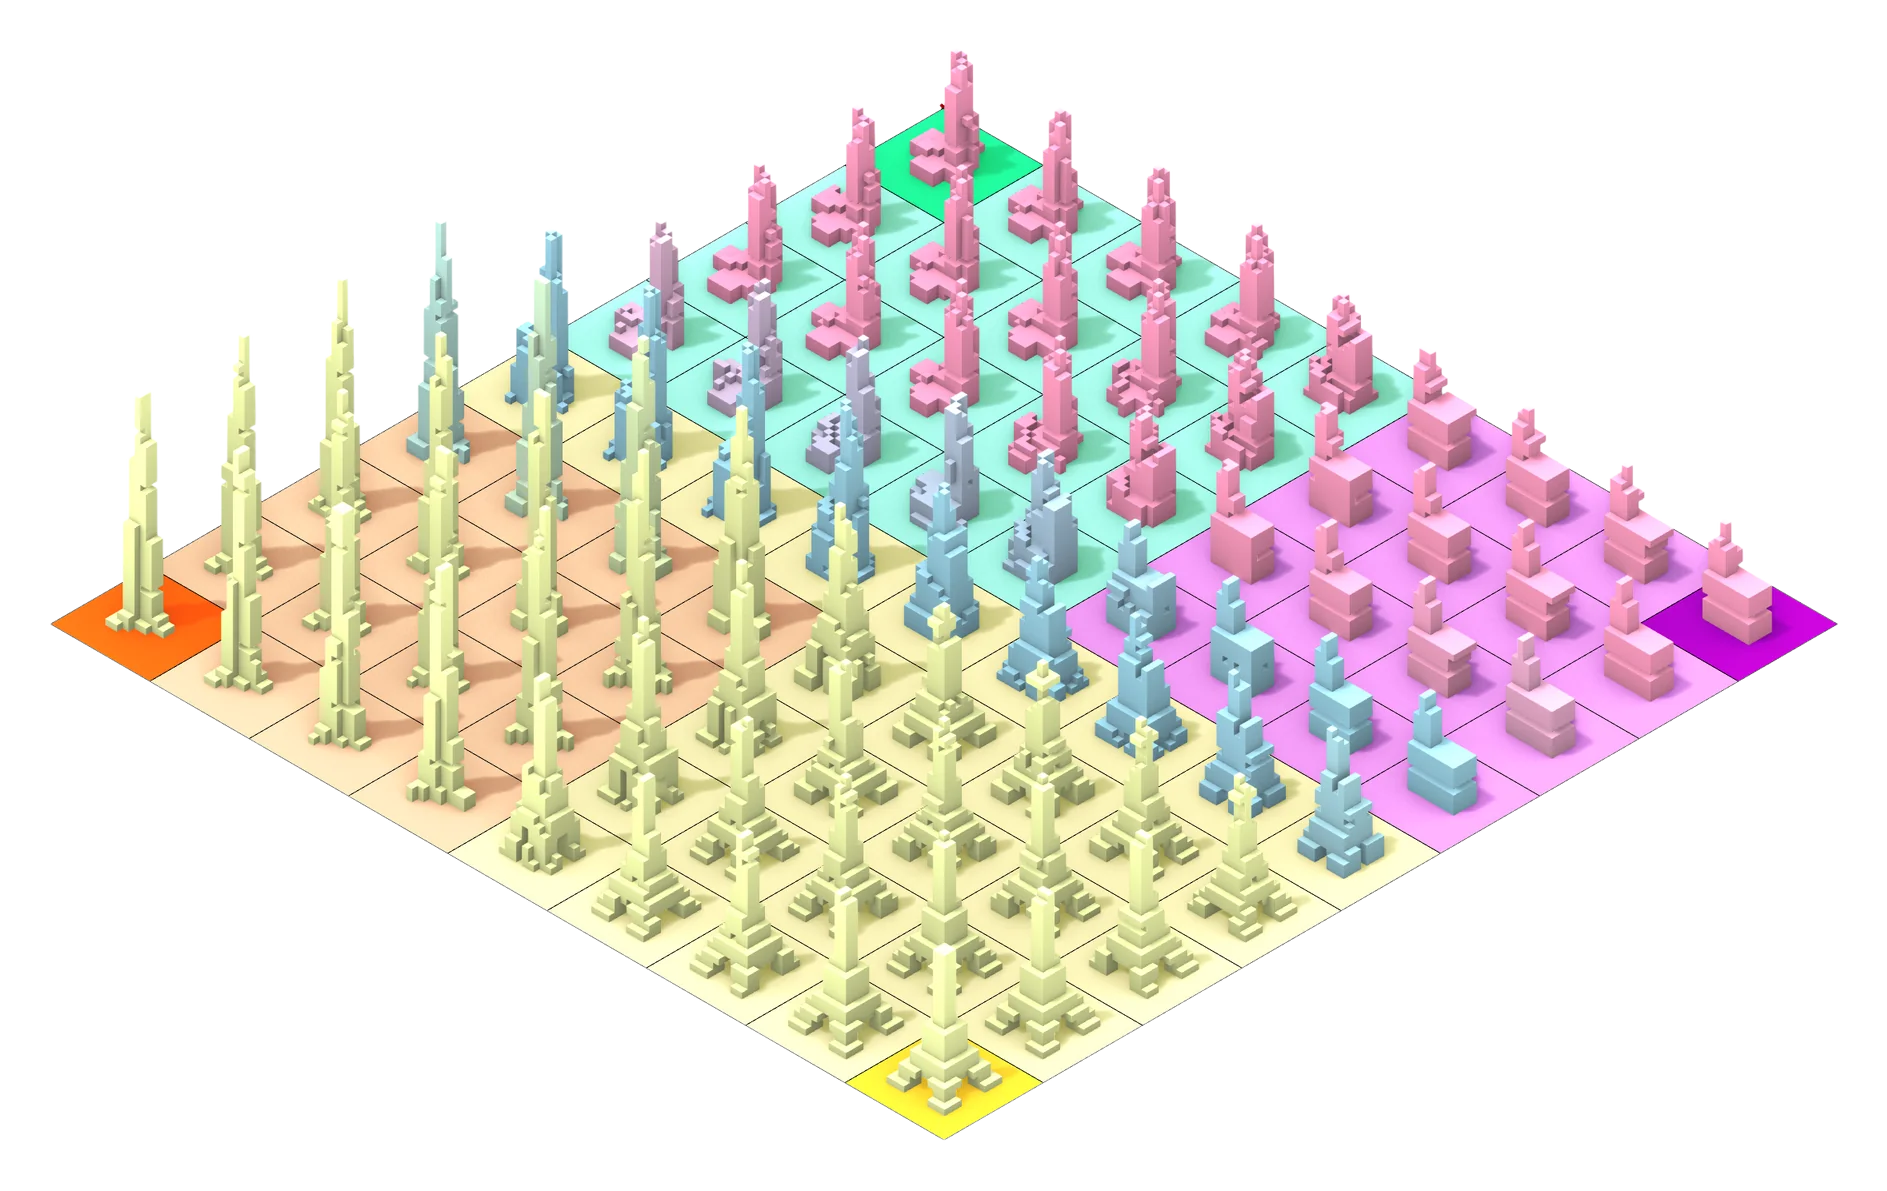
40 × 40 · voxel 31 · 432.9 s · 4 inputs
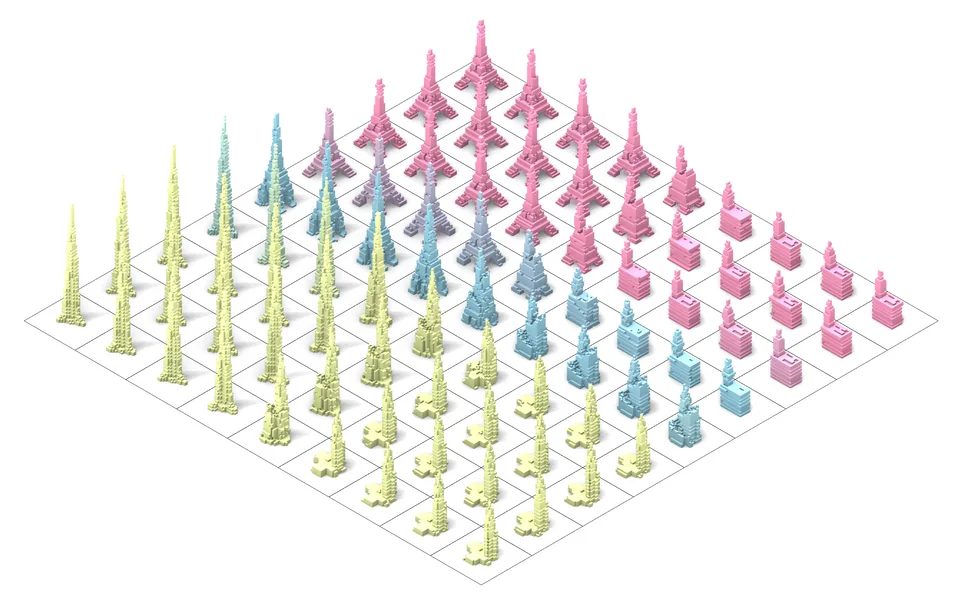
25 × 25 · voxel 15 · 111.4 s · 4 inputs
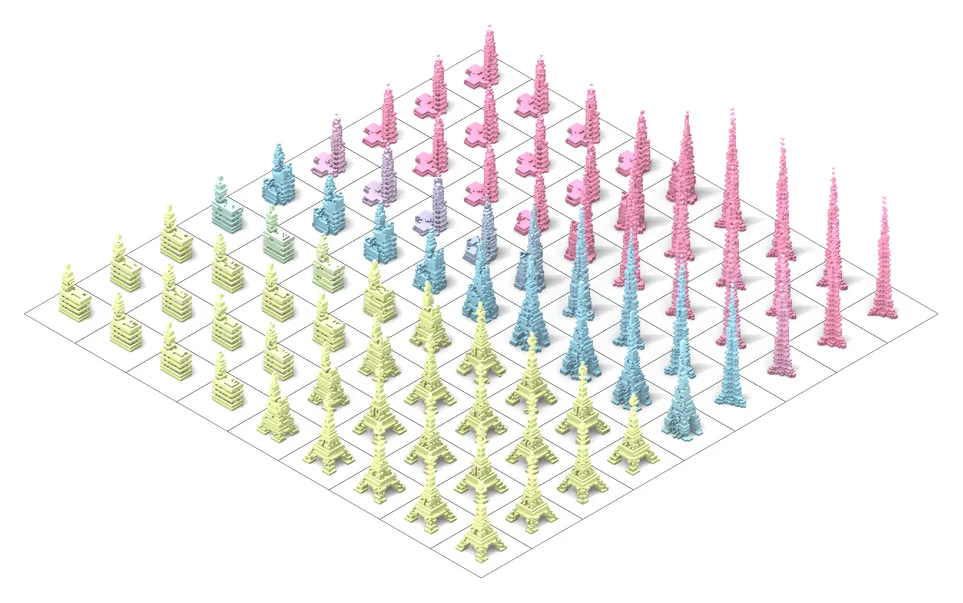
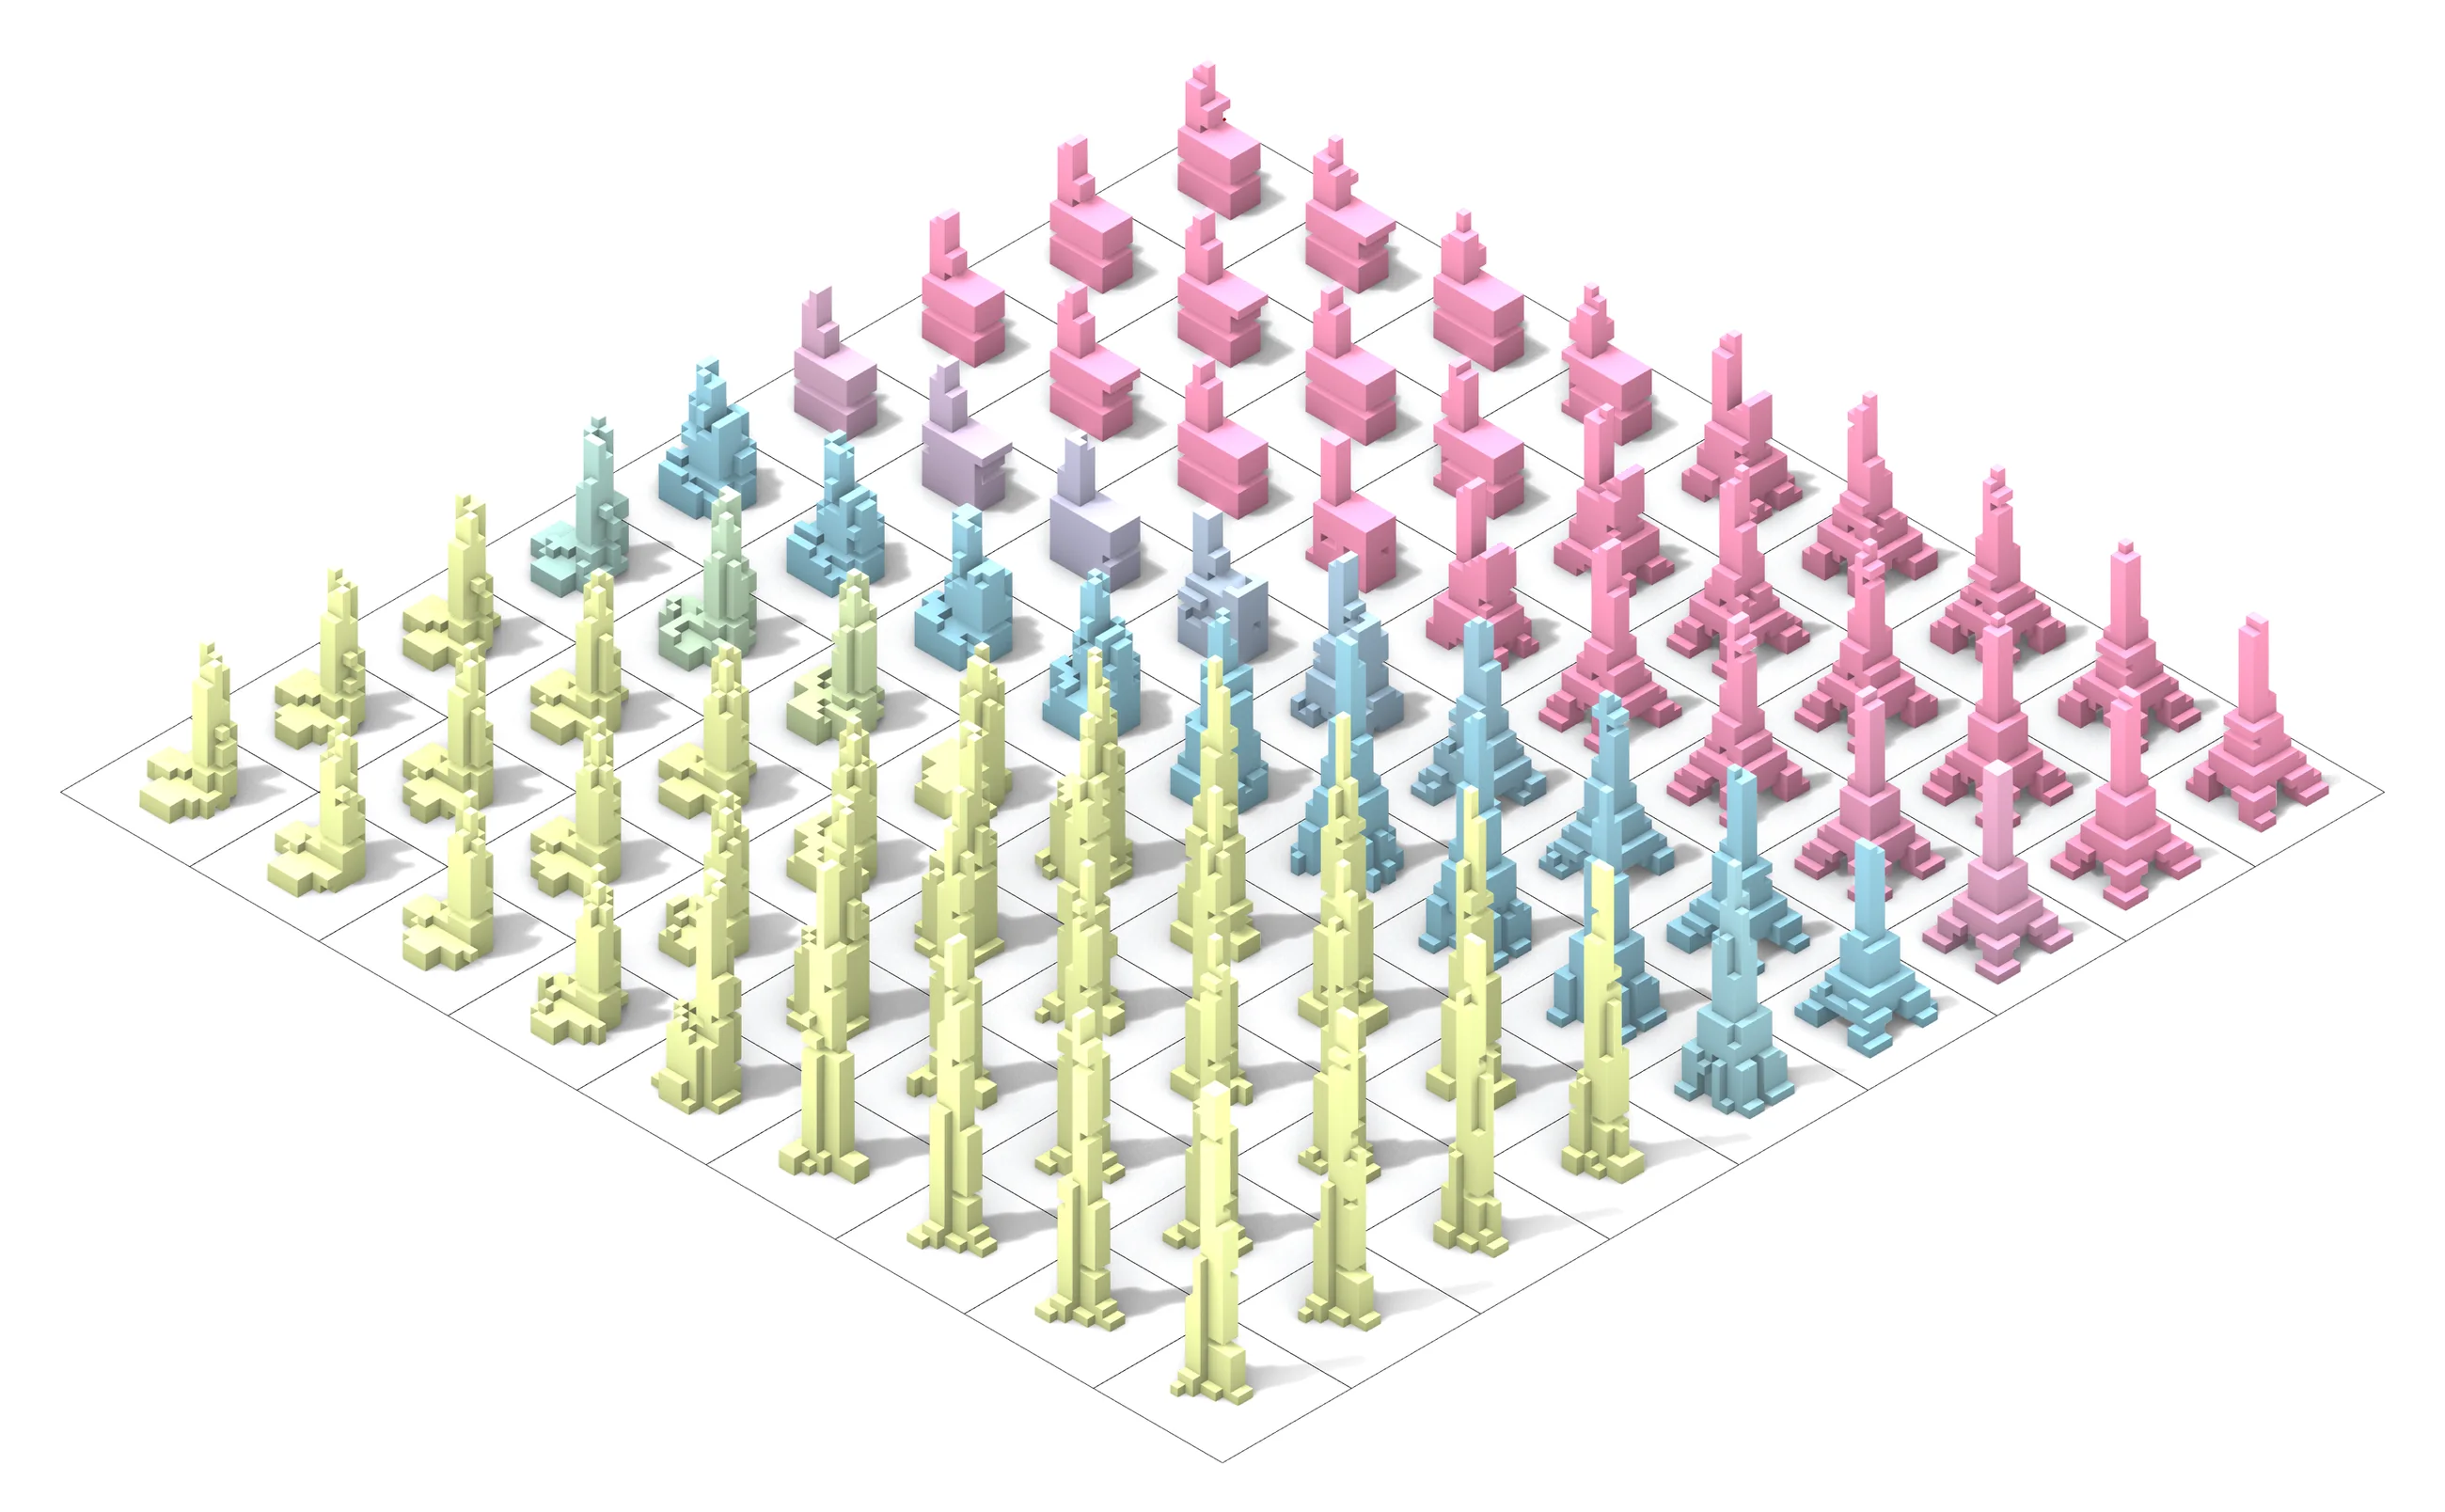
40 × 40 · voxel 15 · 75.2 s · 3 inputs
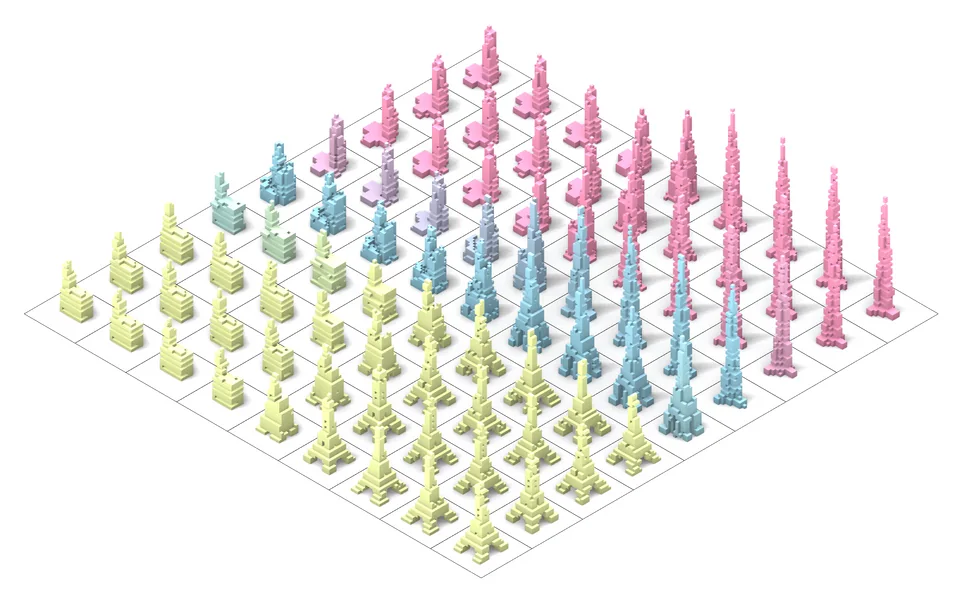
25 × 25 · voxel 25 · 4.8 s · 3 inputs
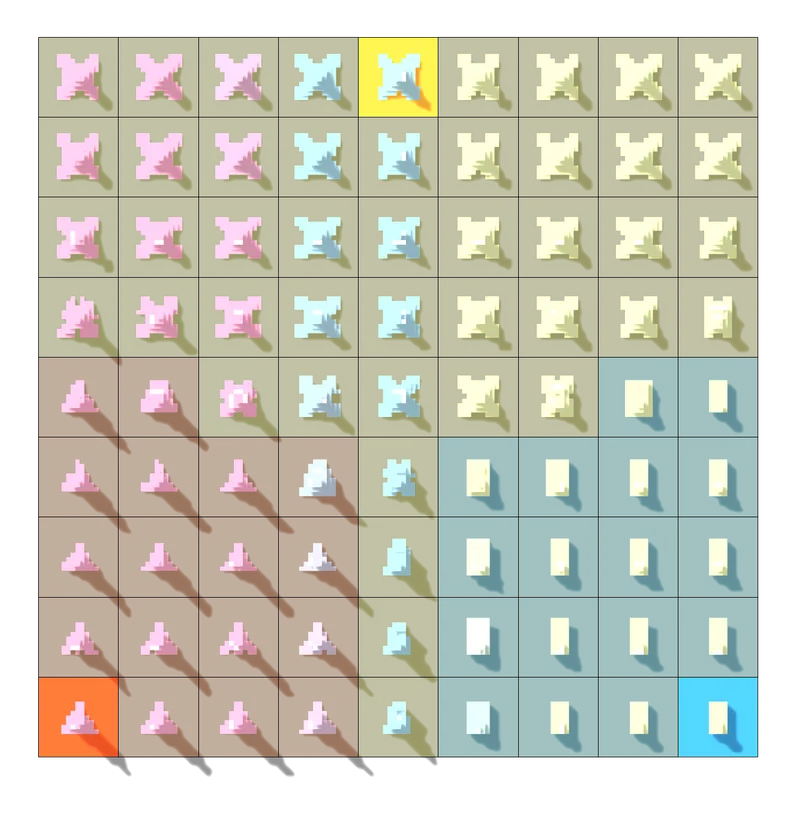
Top view · 4 inputs, clusters as territories
Top view · 3 inputs
The full map · 1,600 voxel forms from four inputs